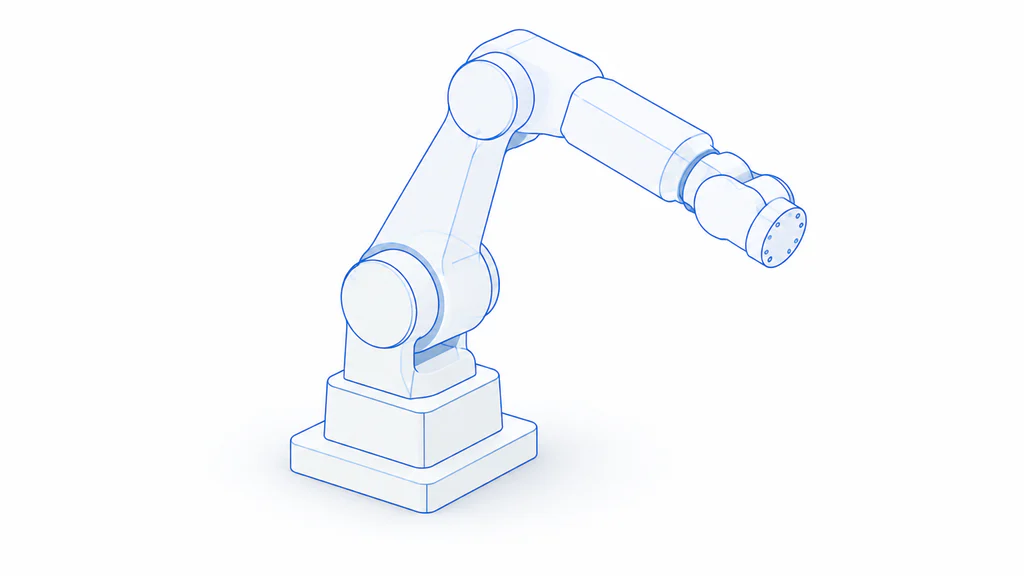
The ME-16 is a collaborative robot arm that picks up and stacks boxes or other items onto pallets in production facilities. An operator configures and controls the robot's stacking patterns using a drag-and-drop software interface rather than writing programming code.