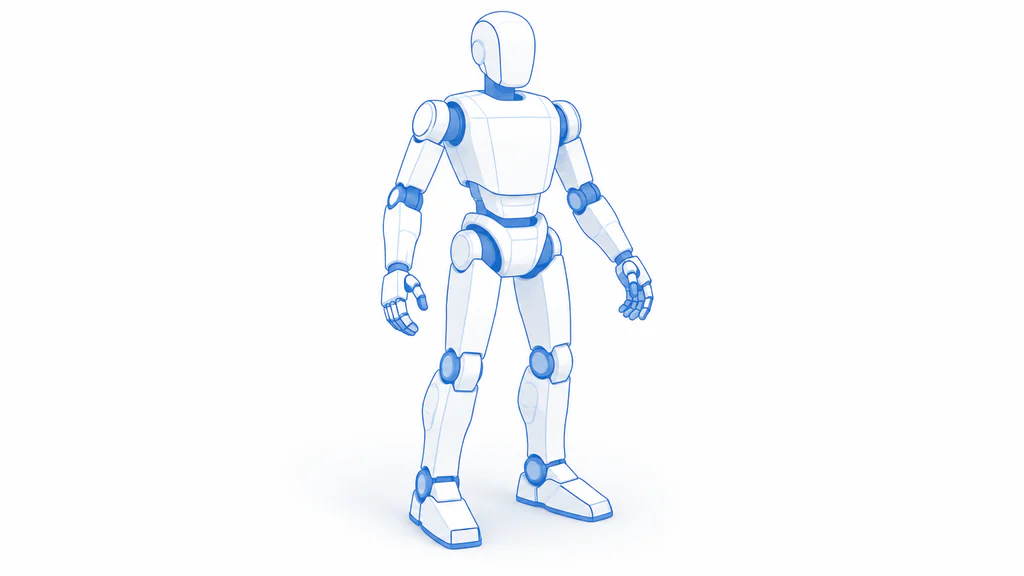
A humanoid robot with hands designed for precise gripping and sensing, built for factory work and research. It operates on its own using visual navigation and can receive instructions to perform production tasks, inspections, and security work in manufacturing facilities and warehouses.